
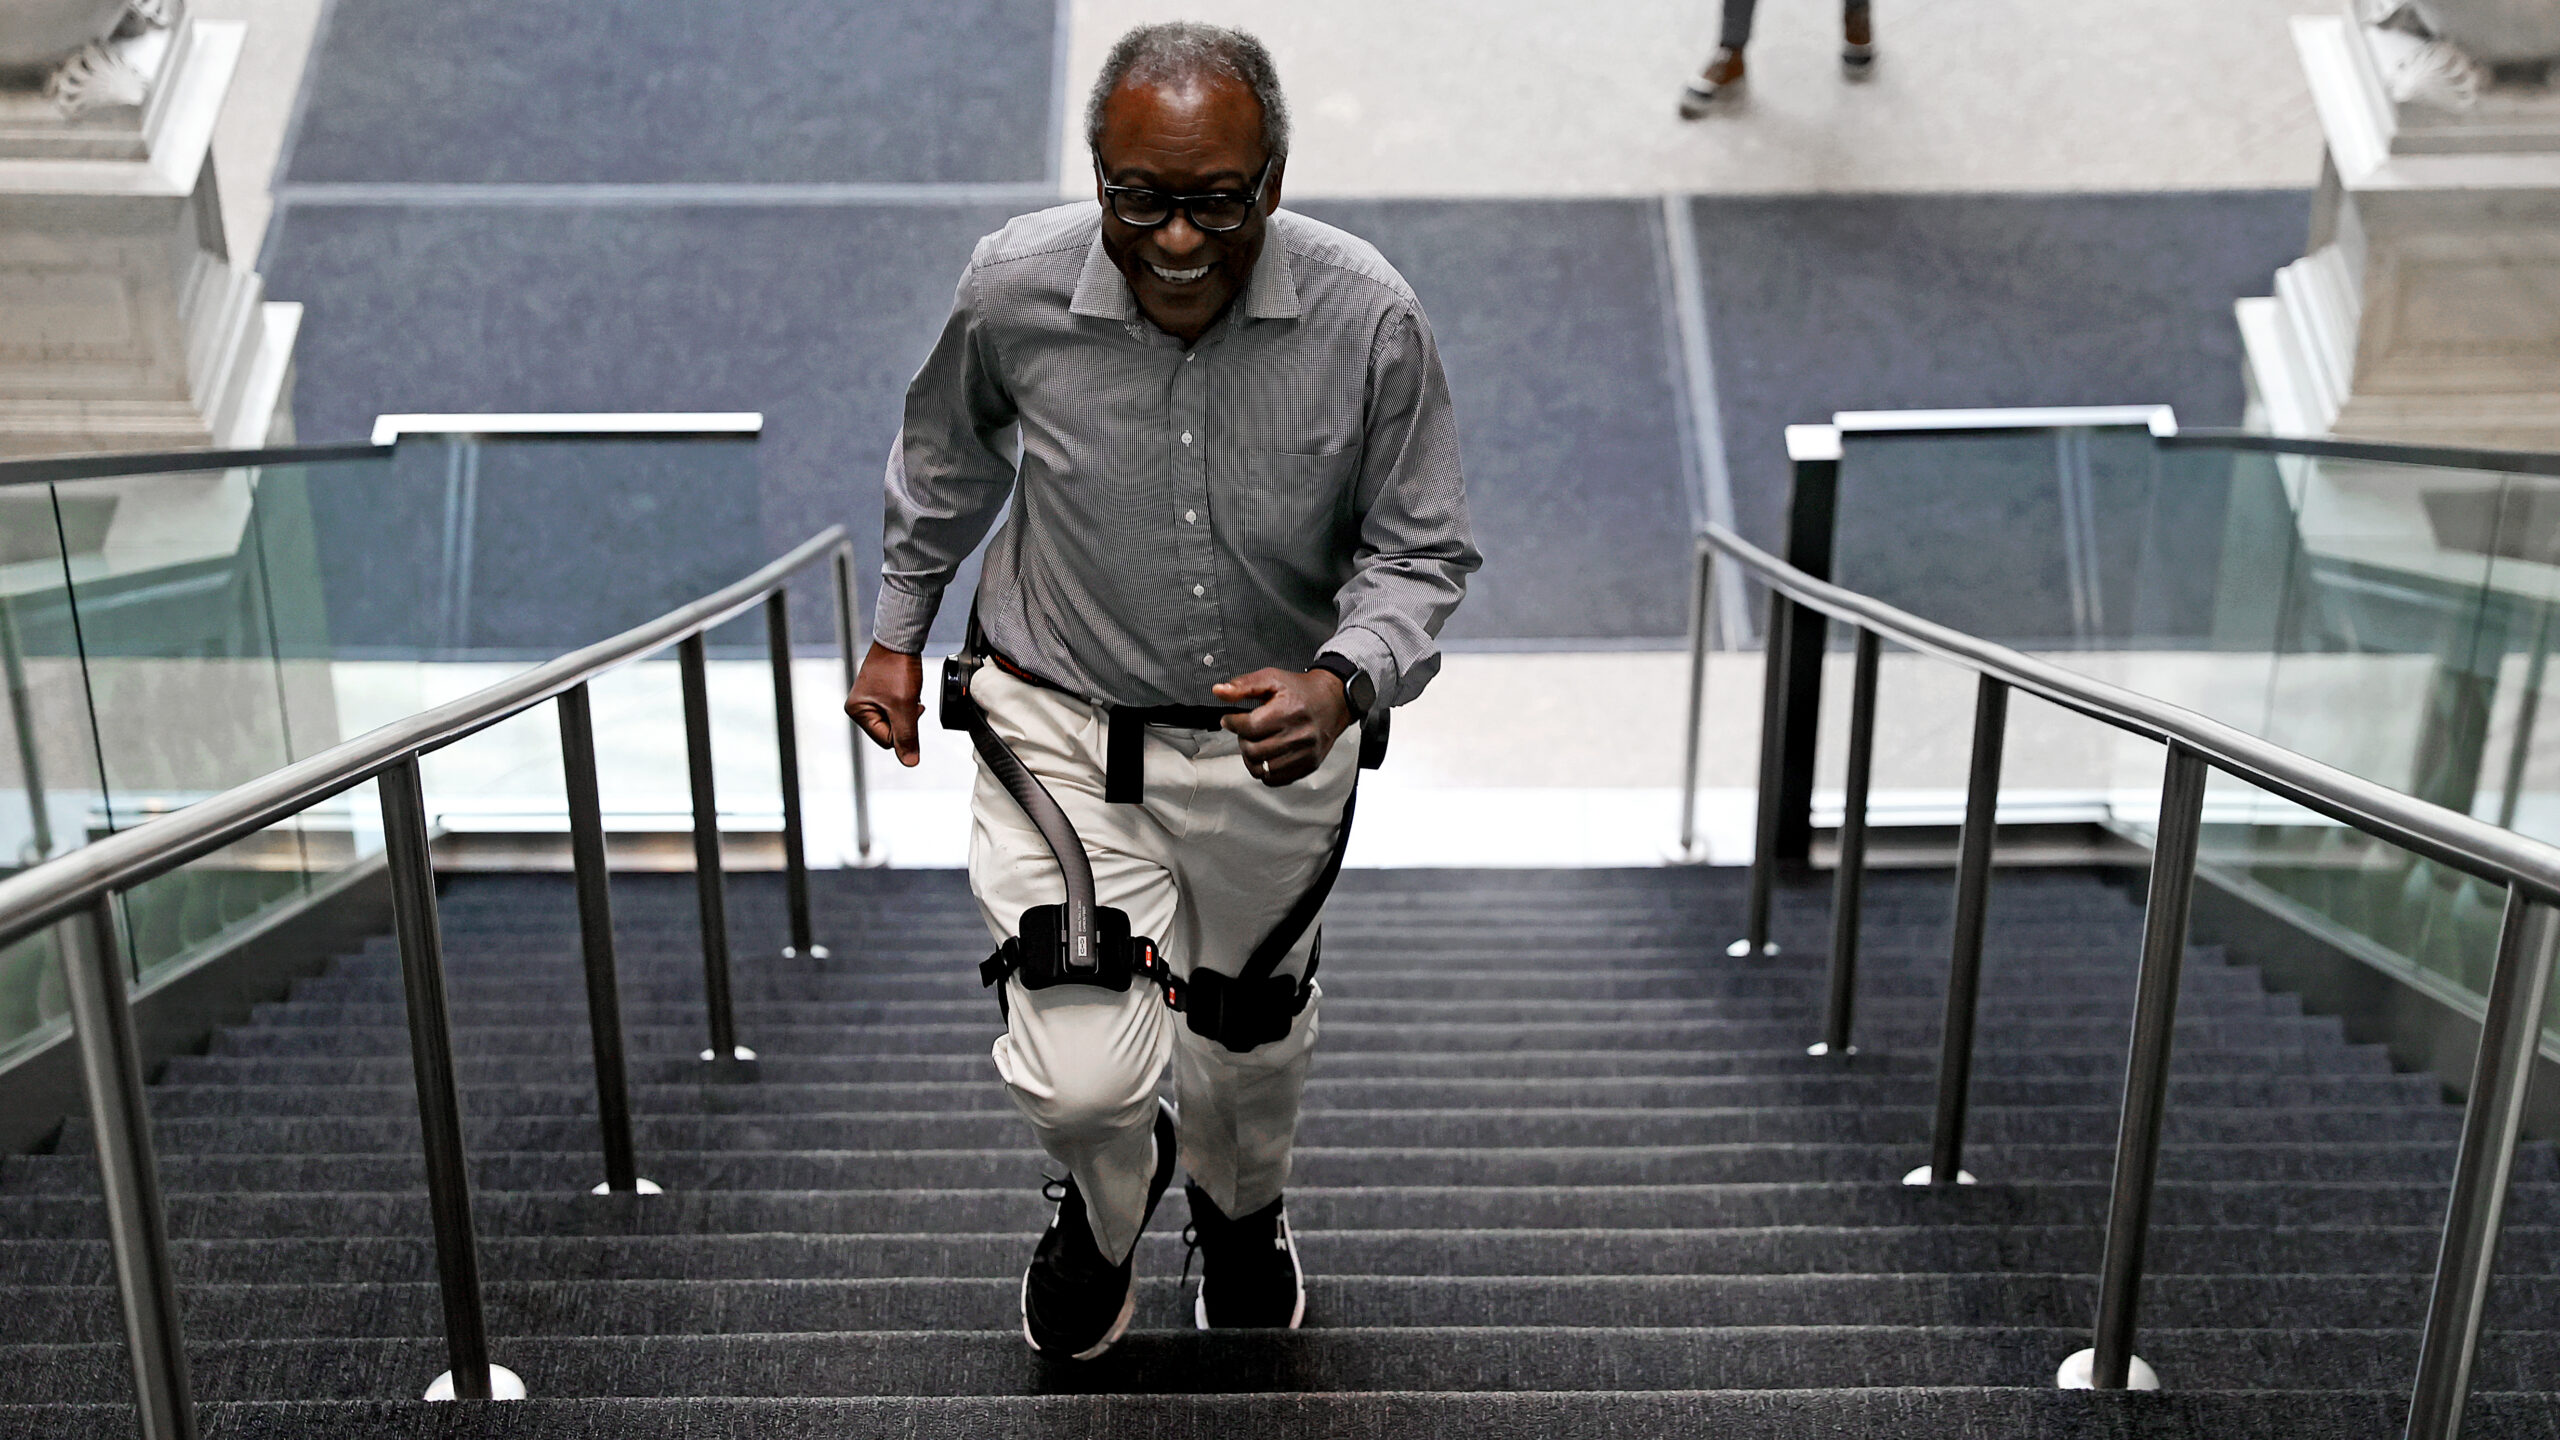
Exoskeletons Evolve With Adaptive Algorithms and Soft Materials
- Wearable robotic exoskeletons are advancing from pre-programmed mechanical frames into adaptive devices that integrate modern materials and sensor-driven controls.
- Exoskeletal assistance generally falls into three distinct operational categories, according to the sourced material.
- Hardware practicality remains constrained by power management requirements.
Wearable robotic exoskeletons are advancing from pre-programmed mechanical frames into adaptive devices that integrate modern materials and sensor-driven controls. While most current systems rely entirely on mechanical feedback loops from built-in sensors, researchers are actively exploring ways to operate these devices using signals drawn directly from a wearer’s muscles and brain.
Exoskeletal Assistance Falls into Three Operational Categories
Exoskeletal assistance generally falls into three distinct operational categories, according to the sourced material. Power augmentation increases a user’s physical force capabilities, a setup commonly found in assistive hardware deployed by companies like IKEA and in Ukraine. Assist-as-needed or resist-as-needed settings deliver body support exclusively when required, which is a configuration frequently utilized in rehabilitation devices to help patients recover lost motor functions. Finally, full robotic control allows an exoskeleton to assume complete movement management over a portion of the user’s body, primarily serving individuals with spinal cord injuries or lost motor capabilities.
Battery Requirements Limit Hardware While Soft Materials Emerge
Hardware practicality remains constrained by power management requirements. Batteries must be integrated directly into the physical frames and regularly recharged, introducing weight and size limits that affect everyday usability, though battery energy density continues to improve steadily. At the same time, engineers are developing new structural configurations built from soft textile or rubber-like materials. These flexible components can be embedded straight into standard clothing, footwear, or protective gear rather than relying entirely on rigid metallic frames.
Robotics Research Continuity
Current developments in wearable technology draw an indirect lineage from walking exoskeleton research conducted during the 1960s and 1970s, which originally contributed to the creation of early humanoid bipedal robots. That historical trajectory has now come full circle. According to Ildar Farkhatdinov, Senior Lecturer in Healthcare Engineering (Robotics and Mechatronics) at King’s College London, acceleration in modern humanoid robotics is directly driving advancements in the actuators and batteries needed for upcoming wearable robotic systems.